
option
Home
Flash News
Content
JustinScott
JustinScott
July 9, 2026

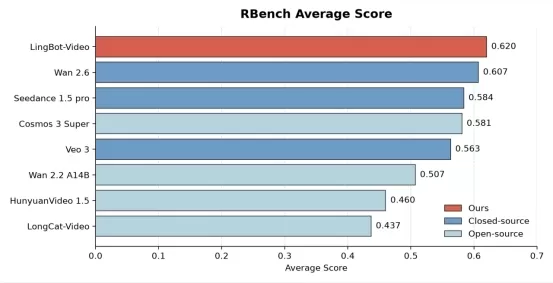
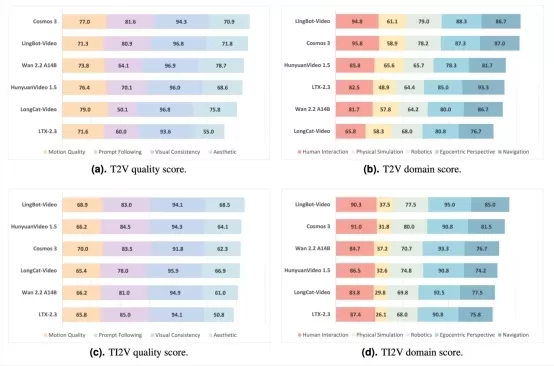
Ant Group open-sourced LingBot-Video, the first video generation foundational model based on a Mixture-of-Experts architecture designed for embodied intelligence. It achieved 0.620 on the RBench benchmark, outperforming Wan2.6 and others. With 30B parameters but activating only 3B per inference, it offers higher reasoning efficiency. Trained on 70,000 hours of embodied data with a multi-dimensional reinforcement learning reward system, it excels in physical plausibility and task completion for robotics.
Ant Group open-sourced LingBot-Video, the first video generation foundational model based on a Mixture-of-Experts architecture designed for embodied intelligence. It achieved 0.620 on the RBench benchmark, outperforming Wan2.6 and others. With 30B parameters but activating only 3B per inference, it offers higher reasoning efficiency. Trained on 70,000 hours of embodied data with a multi-dimensional reinforcement learning reward system, it excels in physical plausibility and task completion for robotics. Ant Group open-sourced LingBot-Video, the first video generation foundational model based on a Mixture-of-Experts architecture designed for embodied intelligence. It achieved 0.620 on the RBench benchmark, outperforming Wan2.6 and others. With 30B parameters but activating only 3B per inference, it offers higher reasoning efficiency. Trained on 70,000 hours of embodied data with a multi-dimensional reinforcement learning reward system, it excels in physical plausibility and task completion for robotics. Ant Group open-sourced LingBot-Video, the first video generation foundational model based on a Mixture-of-Experts architecture designed for embodied intelligence. It achieved 0.620 on the RBench benchmark, outperforming Wan2.6 and others. With 30B parameters but activating only 3B per inference, it offers higher reasoning efficiency. Trained on 70,000 hours of embodied data with a multi-dimensional reinforcement learning reward system, it excels in physical plausibility and task completion for robotics.
Comments (0)
0/300
OR